

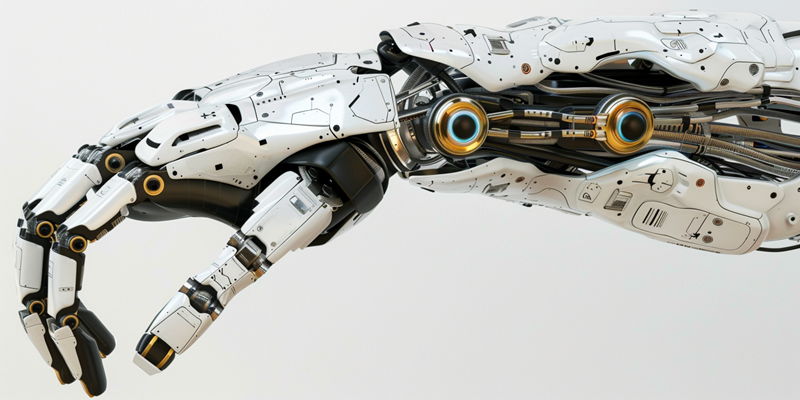
The field of robotic manipulation has evolved rapidly, with significant strides made in recent years. Researchers at the University of Bristol have unveiled a cutting-edge four-fingered robotic hand capable of performing complex manipulations, independent of gravity. This breakthrough, which features a novel tactile sensing system resembling human skin, marks a pivotal advancement in robotic technology. The innovative combination of advanced tactile sensing mechanisms and dexterous manipulation capabilities signifies a quantum leap in robotics, paving the way for myriad applications across various industries.
The Evolution of Robotic Manipulation
The history of robotic manipulation dates back to the pre-1990s, characterized by analytical approaches and 2D modeling. Early robotics primarily focused on basic automation with limited dexterity. As technology advanced, the early 2010s witnessed the advent of multi-fingered end-effectors, which introduced more sophisticated grasping capabilities. Furthermore, by the early 2020s, the integration of deep learning and human-robot interaction further revolutionized the field. Robots began to perform more complex tasks, necessitating the development of sensors that could mimic human touch. This continuous evolution has led to the present innovations, where tactile sensing is intricately blended with advanced manipulation techniques to achieve unparalleled efficiency and precision.
The journey of robotic manipulation from its inception to its current state highlights the relentless pursuit of creating machines that can replicate human abilities. Early efforts concentrated on basic tasks that required minimal dexterity, but as industries demanded more nuanced capabilities, the focus shifted. The advent of multi-fingered end-effectors set the stage for more intricate operations, allowing robots to handle a variety of objects with increased dexterity. The recent incorporation of deep learning algorithms has equipped robots with the ability to learn and adapt to new tasks dynamically, further bridging the gap between human and machine capabilities. This historical backdrop sets the context for the groundbreaking work being done at the University of Bristol.
Biomimetic Tactile Sensing: A Leap Forward
The University of Bristol’s robotic hand incorporates biomimetic tactile sensing, a significant milestone in achieving human-like manipulation. Mimicking the internal mechanics of human skin, the robotic fingers utilize a 3D-printed mesh of papillae beneath synthetic “skin.” This design allows for the nuanced detection of textures and forces, offering a highly sensitive touch. This level of tactile sensitivity is critical for performing tasks that require a delicate touch, ranging from picking up fragile objects to executing precision-based operations. The integration of biomimetic tactile sensing represents a leap forward, setting a new standard for robotic hand functionalities.
3D printing technology plays a crucial role in this development, enabling the combination of hard and soft materials to replicate biological structures more accurately. The result is a robotic hand capable of deftly handling objects with the precision and care of a human hand, making it ideal for both simple and complex tasks. The use of 3D-printed materials allows for customization and refinement, ensuring that the tactile sensors can be tailored to specific applications. This capability is particularly valuable in fields where precise manipulation is essential, such as medical surgeries and delicate assembly processes. The success of this approach underscores the potential of biomimetic designs in advancing robotic technologies.
Overcoming Gravity: Experimental Insights
Initial tests for the robotic hand focused on manipulating objects in gravity-defying orientations. This posed a unique challenge, requiring the system to adapt and function effectively without the usual gravitational cues. Through targeted training sessions, the robotic hand managed to adjust, showcasing its ability to handle objects upside down. This adaptability highlights the robustness of the tactile sensing system, which relies on real-time feedback to adjust the grip and manipulation techniques. The success of these tests underscores the potential for such technology to operate in varied environments, including space and underwater scenarios, where traditional robotic systems may struggle.
The ability to function without gravitational cues opens up a plethora of possibilities for this robotic hand. In space exploration, for instance, robots equipped with such advanced tactile sensing and manipulation capabilities could undertake tasks that are currently deemed too risky or complex for human astronauts. Similarly, in underwater research, where buoyancy and fluid dynamics add layers of complexity, these robots could perform intricate operations with ease. The experimental insights gained from these tests demonstrate the versatility and potential of the University of Bristol’s robotic hand, cementing its place as a groundbreaking innovation in the field of robotics.
The AnyRotate System: Enhancing Dexterity
Another key feature of the University of Bristol’s robotic hand is the AnyRotate system, designed to enable in-hand manipulation of objects along multiple axes, irrespective of gravity. This system leverages complex datasets, including tactile images, contact forces, and robot poses, to train a Convolutional Neural Network (CNN). By analyzing this data, the CNN improves the robotic hand’s dexterity and accuracy. This allows it to perform intricate movements and adjust its approach based on the object’s characteristics. The AnyRotate system represents a significant advancement, enabling robots to handle objects with a level of finesse previously unattainable.
The CNN’s ability to process and learn from tactile feedback is crucial for the robotic hand’s performance. By continuously refining its grip and manipulation techniques, the robot can adapt to new objects and tasks with minimal reprogramming. This adaptability is particularly valuable in dynamic environments where the robot must interact with a variety of objects under different conditions. The AnyRotate system, therefore, not only enhances the robotic hand’s capabilities but also extends its range of applications. This advanced manipulation capability signifies a step forward in achieving robots that can autonomously execute tasks with human-like finesse, making them invaluable tools in industrial and research settings.
Real-World Applications and Future Prospects
The field of robotic manipulation has made remarkable progress, particularly in recent years. At the forefront of this advancement, researchers at the University of Bristol have introduced an innovative four-fingered robotic hand. This state-of-the-art device is capable of performing intricate manipulations without relying on gravity. A key aspect of this breakthrough is its novel tactile sensing system, which mimics the sensitivity of human skin, enabling the robot to carry out tasks with unprecedented precision and agility. The combination of these advanced tactile sensors and the hand’s dexterous manipulation capabilities represents a significant leap forward in robotics technology. This development has far-reaching implications, potentially transforming various industries by offering new solutions in fields like manufacturing, healthcare, and even space exploration. The University of Bristol’s creation exemplifies how cutting-edge research can lead to practical applications that revolutionize the way we interact with robots, making this an exciting time in the ongoing evolution of robotic technology.